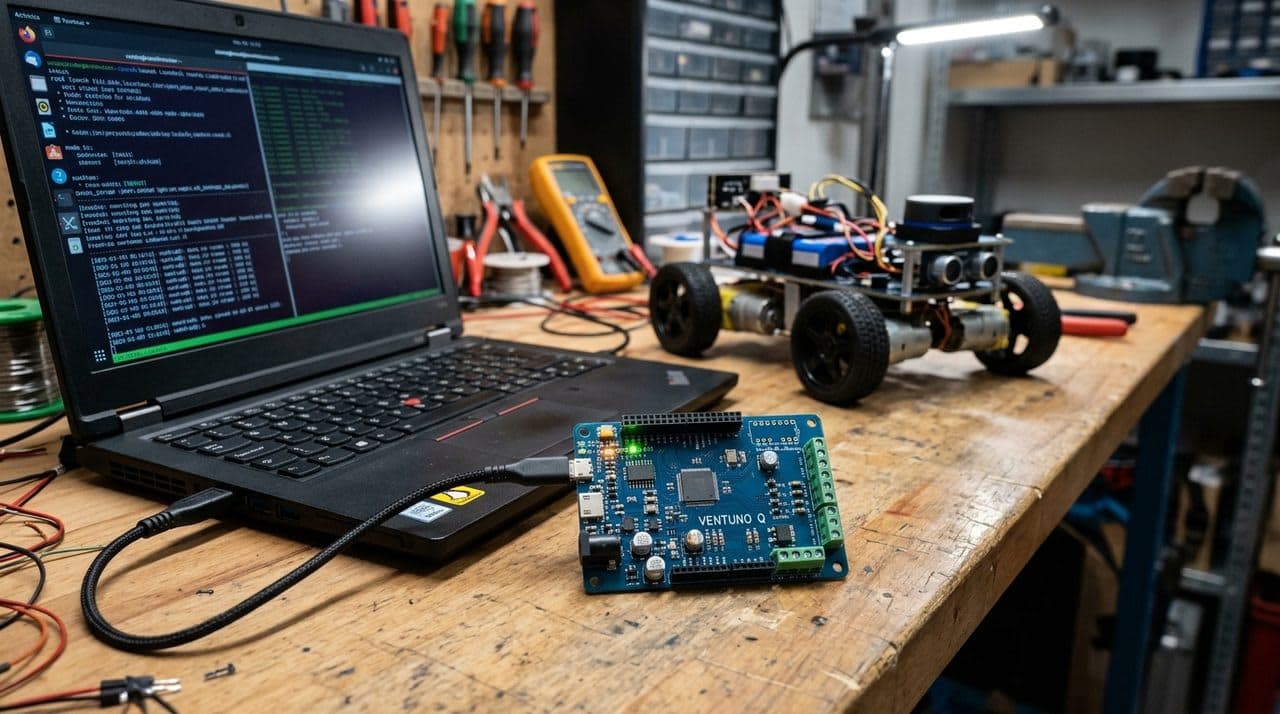
When you build a robot with ROS 2, the architecture is usually split in two: a Linux box does high‑level navigation, mapping, and planning, while an external microcontroller handles real‑time GPIO, sensors, and motor control.
Making those two worlds talk often means custom serial protocols, dedicated drivers, or bulky bridge nodes. The Arduino® VENTUNO Q board was created to remove that pain point.
Dual‑brain hardware for ROS 2
VENTUNO Q combines a Linux‑capable MPU and a real‑time MCU on the same board, giving you a true dual‑brain platform. At ROSCon Global 2026 in Toronto, and later at ROSCon Italy, Giovanni Bruno introduced a new open‑source tool that ties this hardware directly into ROS 2: the Arduino_RouterBridge_ROS library.
Under the hood sits Arduino_RouterBridge, which implements an RPC protocol on top of MsgPackRPC. It lets the Linux side (Python) and the MCU side (Zephyr‑based Arduino sketch) execute functions on each other via two simple calls:
Bridge.provide()– register a callable function on one sideBridge.call()– invoke that function from the other side
No more hand‑rolled serial parsers: you just call functions across the MPU/MCU boundary as if they ran in the same thread.
Writing ROS 2 nodes inside your Arduino sketch
Built on this transport, Arduino_RouterBridge_ROS exposes a lightweight ROS 2 proxy that plugs your firmware straight into the ROS graph using the familiar ros2ino namespace:
- Full node features: create nodes, publishers, subscribers, services, and actions on the MCU
- RMW‑agnostic: works with any ROS Middleware you choose on Linux
- Native C++ API: mirrors standard rclcpp patterns
Your real‑time code can now publish topics like /imu/data or subscribe to /cmd_vel directly, without extra bridge nodes.
Whether you’re building an autonomous rover, a precision robotic arm, or your first ROS‑powered bot, grab a VENTUNO Q, check out the Arduino_RouterBridge_ROS repo, and follow the docs (“Getting Started with ROS 2 on UNO Q”, “First ROS 2 Project on UNO Q”) to get moving fast.
Source: Arduino Blog